Introduction
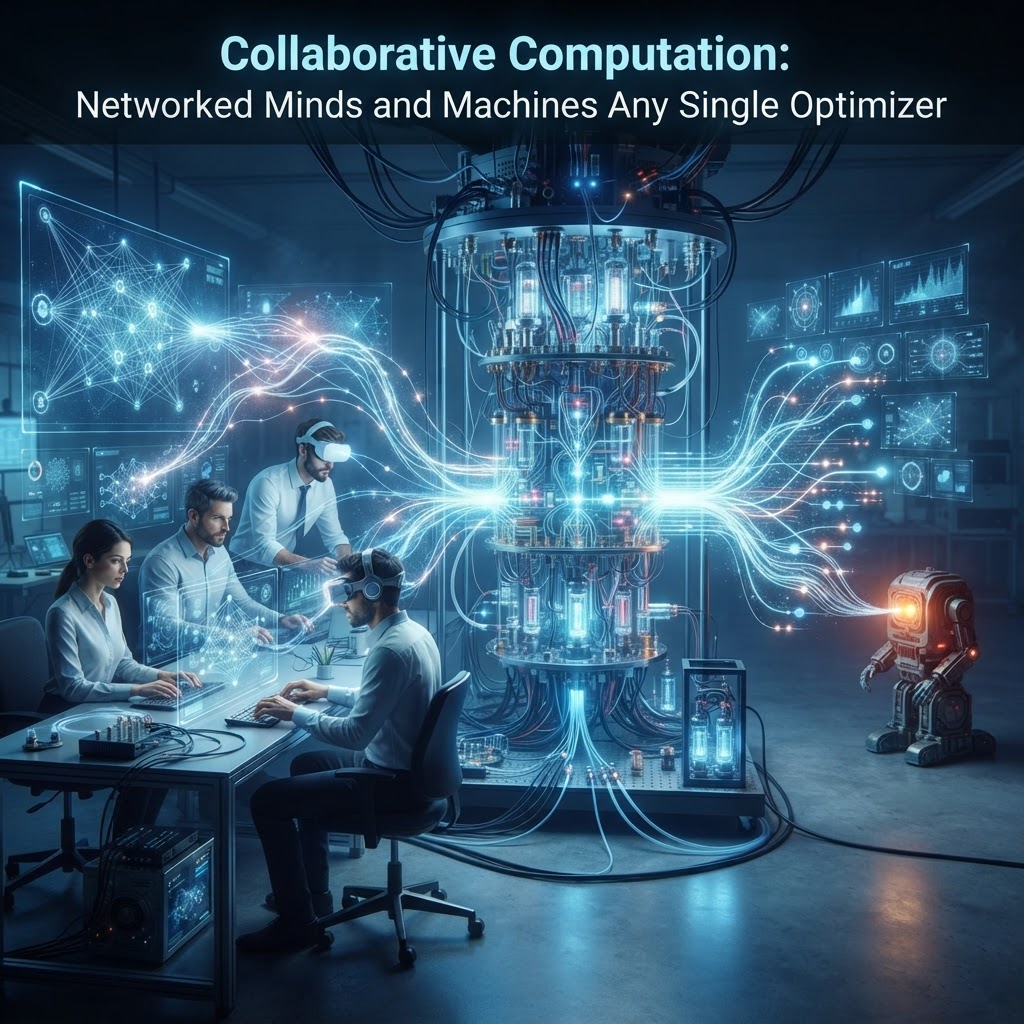
For decades the dominant metaphor in computation has been the solitary optimizer: a single algorithm, running on ever-larger hardware, progressively squeezing performance from a problem. That model works when the search surface is smooth, the objective is singular, and scale maps predictably to improvement. But many of today's frontier problems—protein folding, climate model calibration, novel materials search, and policy optimization in multiagent environments—are nonconvex, noisy, ambiguous, and inherently multiobjective. In these spaces, a different architecture wins: collaborative computation, where diverse agents (human and machine) communicate, propose, critique, and combine partial solutions.
The mechanics of collaboration
Why does a networked ensemble of solvers outperform a single optimizer? The reasons are structural and statistical.
Diversity of heuristics. Different optimizers bring different inductive biases and failure modes. An evolutionary search explores broadly and tolerates noise; gradient-based methods exploit local smoothness; constraint solvers enforce hard feasibility; human experts inject domain heuristics. When these complementary strategies interact—via shared memory, consensus voting, or staged pipelines—they cover one another's blind spots.
Variance reduction and robustness. Ensembles reduce estimator variance and can make decisions more robust to adversarial or spurious gradients. In optimization terms, collaboration widens the effective basin of attraction and lowers the chance of being trapped in deep local minima.
Communication protocols matter as much as the agents themselves: synchronous averaging, asynchronous proposal-acceptance, reputational weighting, and market-like scoring change how information flows and which ideas propagate.
Evidence from practice
Concrete systems already demonstrate this principle. Foldit—an online protein-folding game—paired human puzzle-solvers with computational scoring functions and produced novel, experimentally validated protein structures that automated systems missed (Cooper et al., 2010). DeepMind's AlphaFold achieved breakthrough accuracy in structure prediction, but its development and validation relied on community data, human-curated alignments, and hybrid pipelines (Jumper et al., 2021).
In machine learning, ensembles and mixture-of-experts architectures routinely outperform single models on robustness and calibration metrics. Federated learning demonstrates that decentralized, heterogeneous data combined via communication-efficient aggregation can produce models that respect privacy while improving generalization (McMahan et al., 2017). In optimization research, particle swarm and multiagent reinforcement learning approaches show that simple interacting agents can solve nonconvex problems that defeat centralized optimizers (Kennedy & Eberhart, 1995; Zhang et al., 2019).
Design principles for collaborative compute architectures
Moving from ad hoc ensembles to systemic collaborative platforms requires engineering intentionality. Key design principles:
1. Heterogeneity by design. Build toolchains that intentionally combine gradient-based optimizers, derivative-free search, constraint solvers, symbolic engines, and human-in-the-loop modules.
2. Lightweight, information-rich communication. Transfer of raw parameters is costly and often harmful; instead share features, critiques, uncertainty estimates, and compact proposals.
3. Adaptive arbitration. Use meta-optimizers or market-like mechanisms to weight contributions dynamically based on performance, novelty, and resource cost.
4. Incentives and trust. When humans participate, design clear feedback, reputation systems, and auditability so that useful heuristics propagate.
Why collaboration scales where brute force doesn't
Adding compute to a single optimizer has diminishing returns in rugged landscapes. Collaborative architectures, however, enable qualitative gains: cross-agent exploration can find fundamentally different basins; human intuition can suggest algorithmic transformations; lightweight communication can steer search away from known traps. Practically, this means better sample efficiency, broader solution diversity, and more resilient performance under distribution shift.
Open challenges and risks
Collaboration is not a panacea. Coordinating many actors introduces overhead, synchronization fragility, and new attack surfaces. Questions remain about optimal communication topologies, when to prefer centralized aggregation versus peer-to-peer negotiation, and how to certify correctness when proposals are emergent from many opaque subsystems. There are also sociotechnical risks: incentive misalignment can reward conformity or gaming rather than creativity, and aggregated systems can magnify bias if diverse perspectives are not actively preserved.
Conclusion
Computation is entering an era where cooperation outcompetes domination. For hard, real-world problems, architectures that combine heterogeneous algorithms, human expertise, and adaptive communication protocols create solutions a lone optimizer cannot. The future of high-performance computing and AI will be less about building ever-larger, monolithic solvers and more about engineering rich ecologies of collaborating agents—each imperfect, but collectively superior.
Designing those ecologies—balancing diversity, communication efficiency, and incentive alignment—is the central engineering challenge of the next decade.